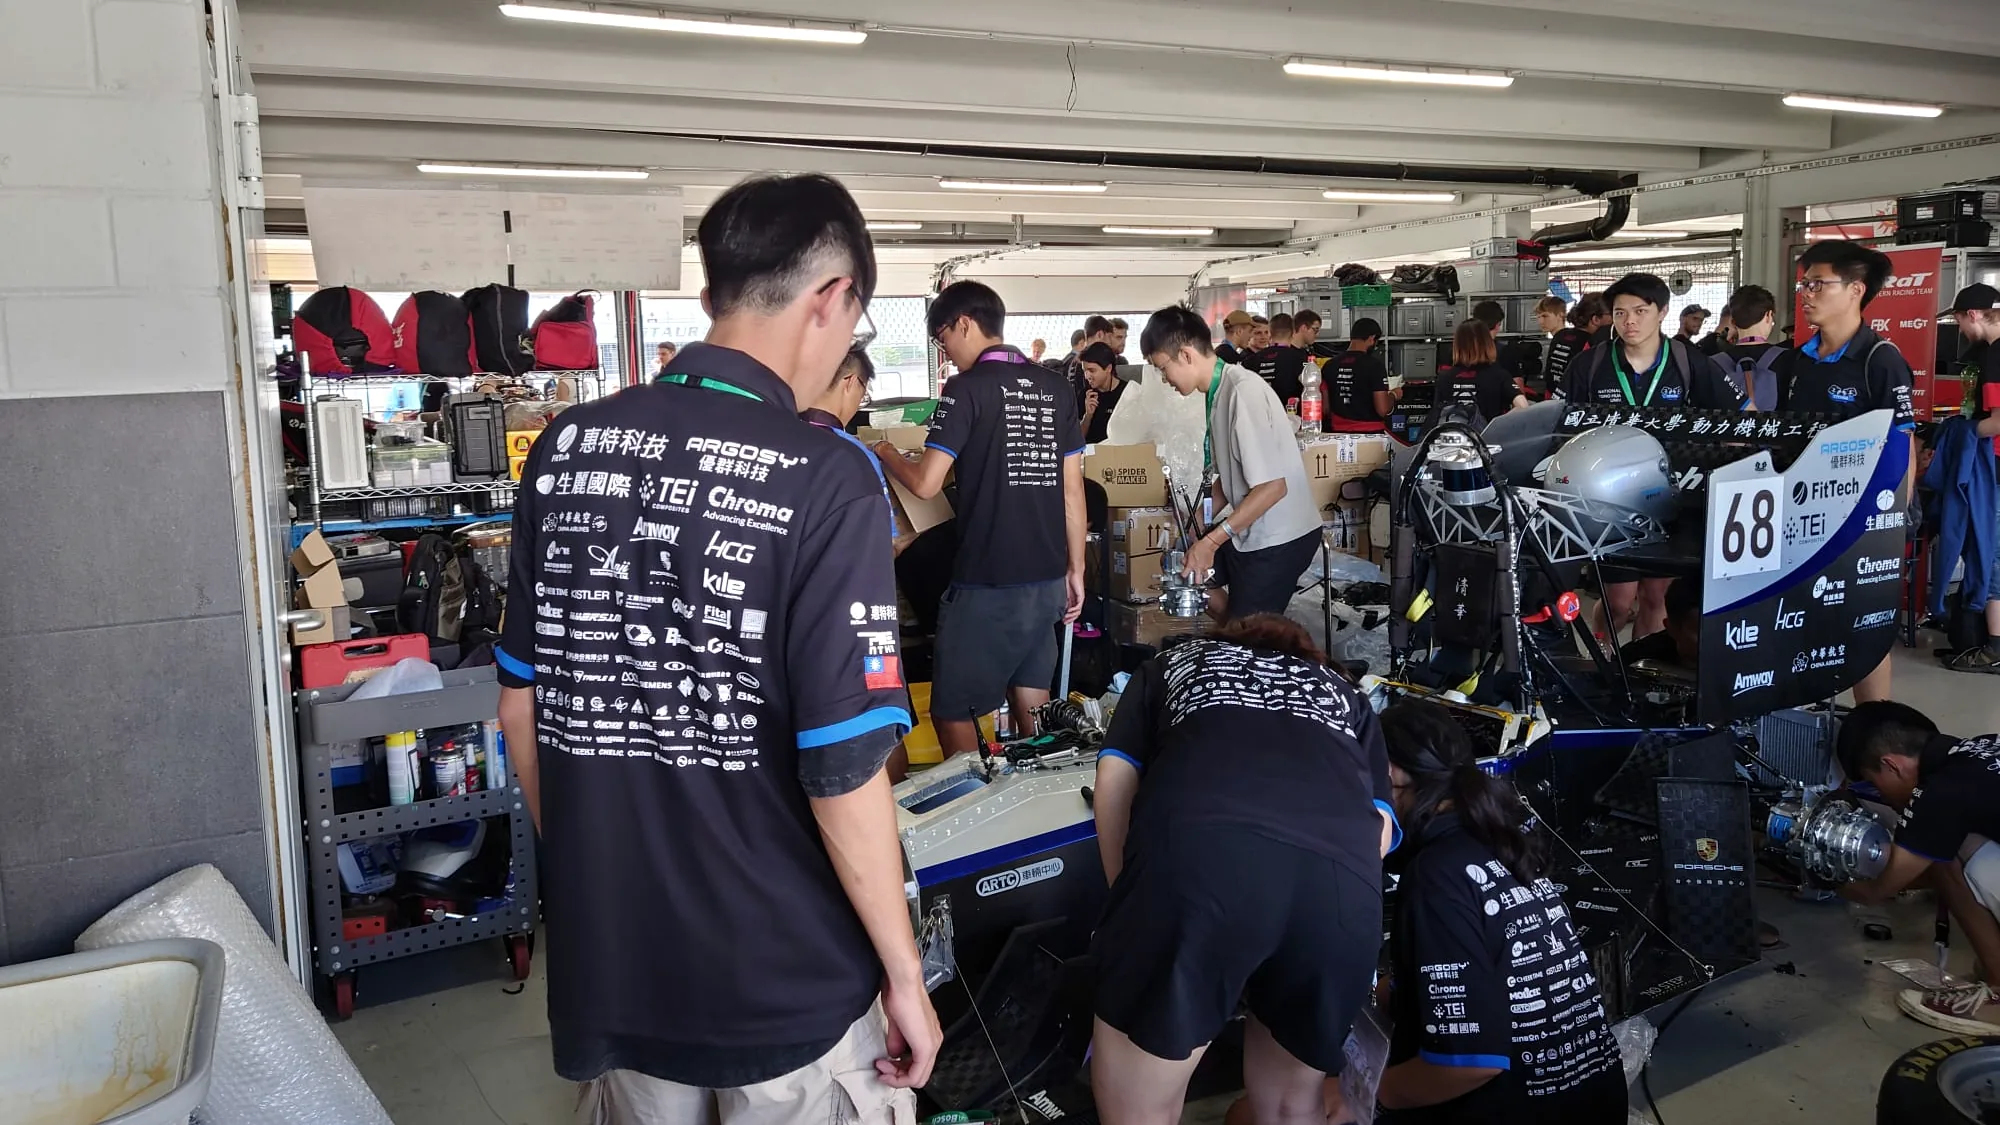
Formula Student
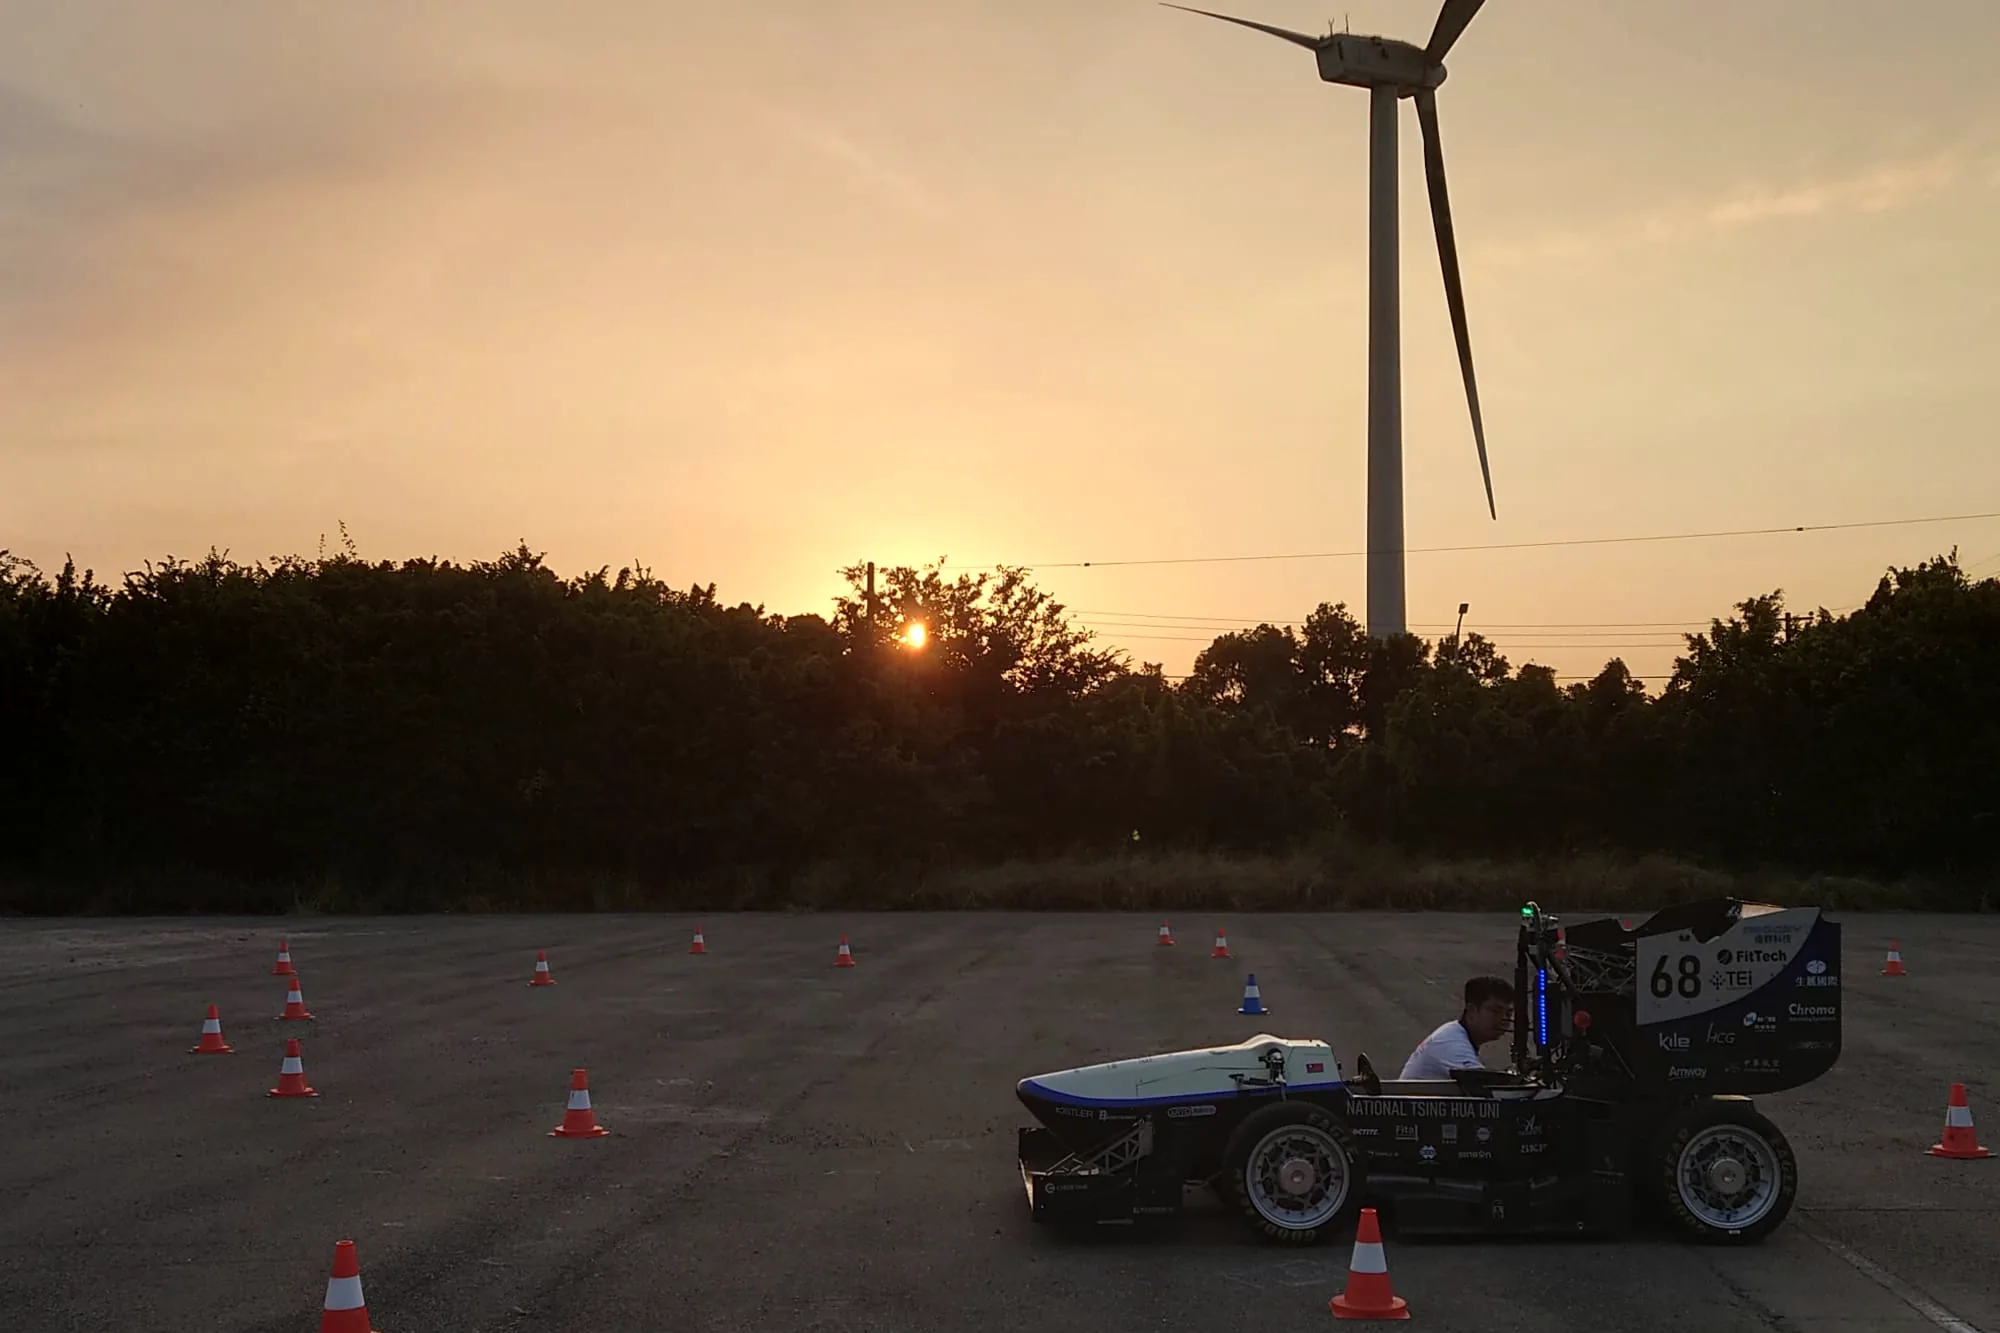
A member of both the autonomous and the electrical teams of NTHU’s Formula Student car: learning algorithms and electrical engineering at the same time, and researching problems no one on the team had solved before.
What I did
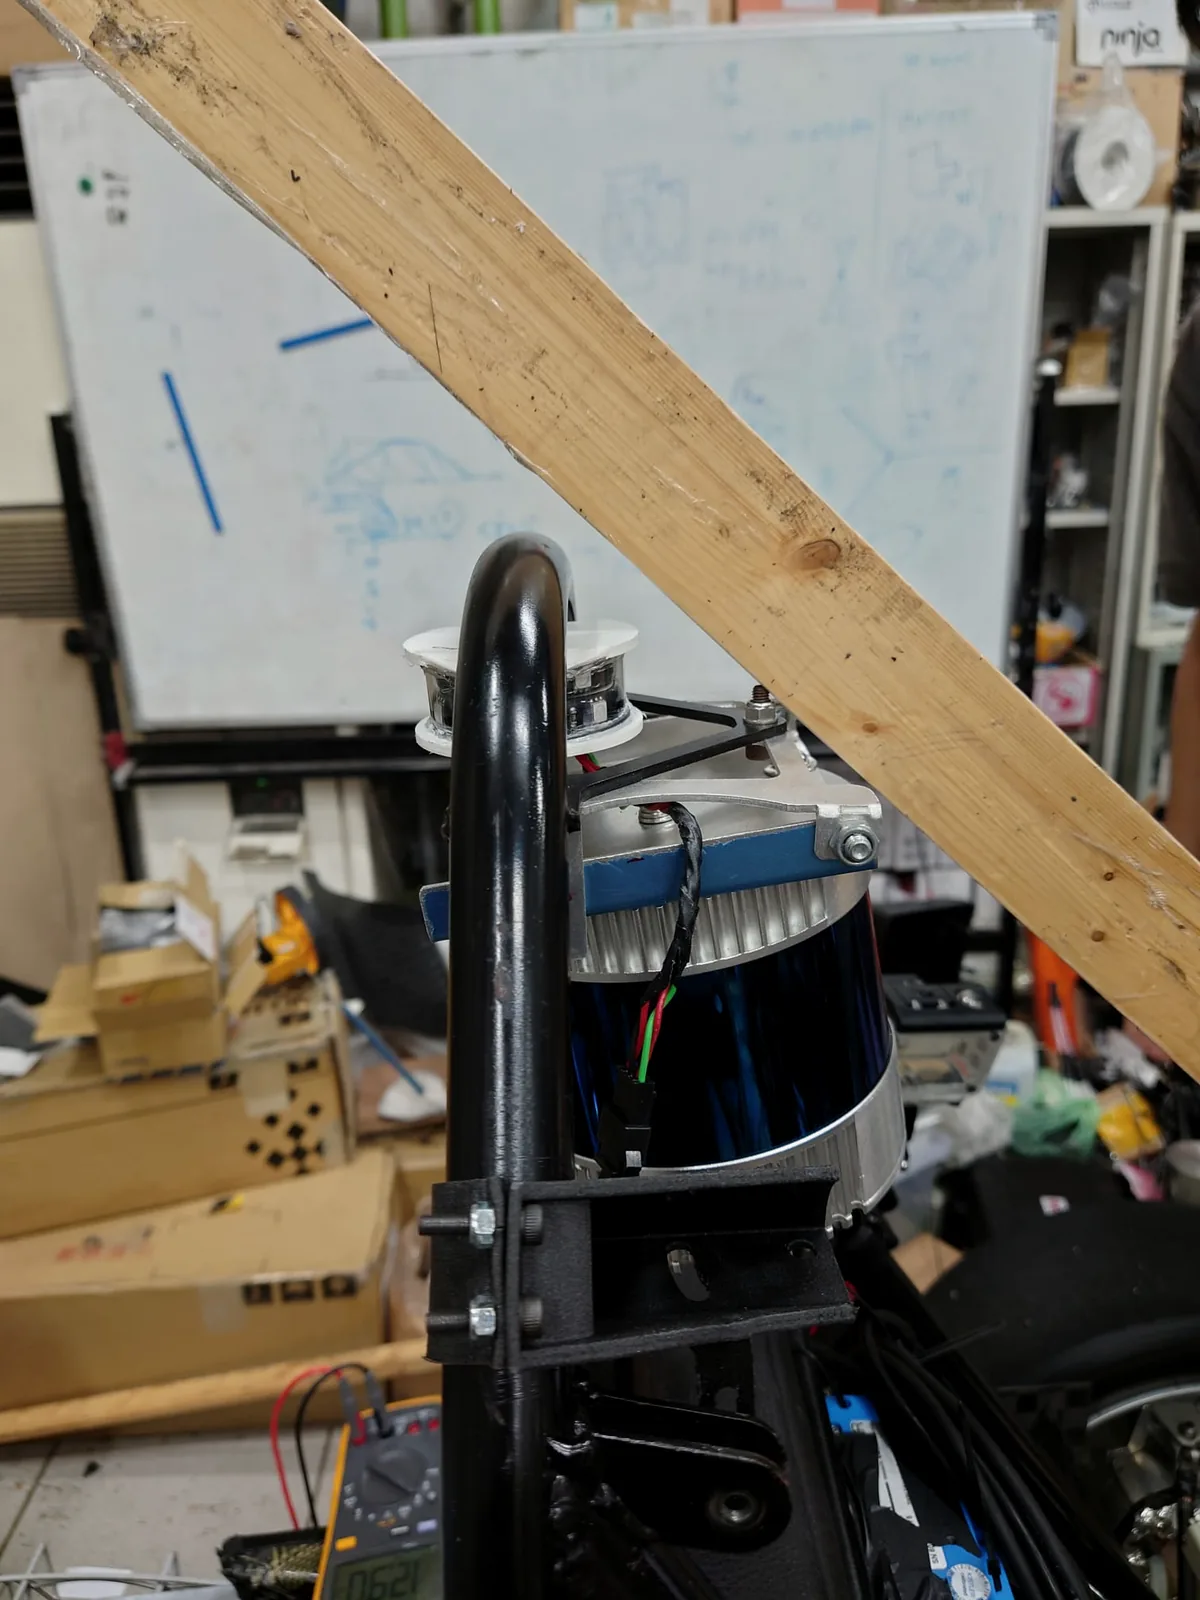
I designed the mount for the autonomous hardware. What looked like a simple component involved balancing weight, technical inspection requirements and the LiDAR’s field of view: its position had to let it see what the autonomous system needed.
I also helped calibrate the camera. Because we were using a wide lens, the lens distortion was significant, and the contrast also needed correcting. Calibration solved this fundamental problem for the team’s image processing.
I was also responsible for choosing the correct components, from the lens and camera to the piping for the autonomous braking system, and I helped wire the car and solder components.